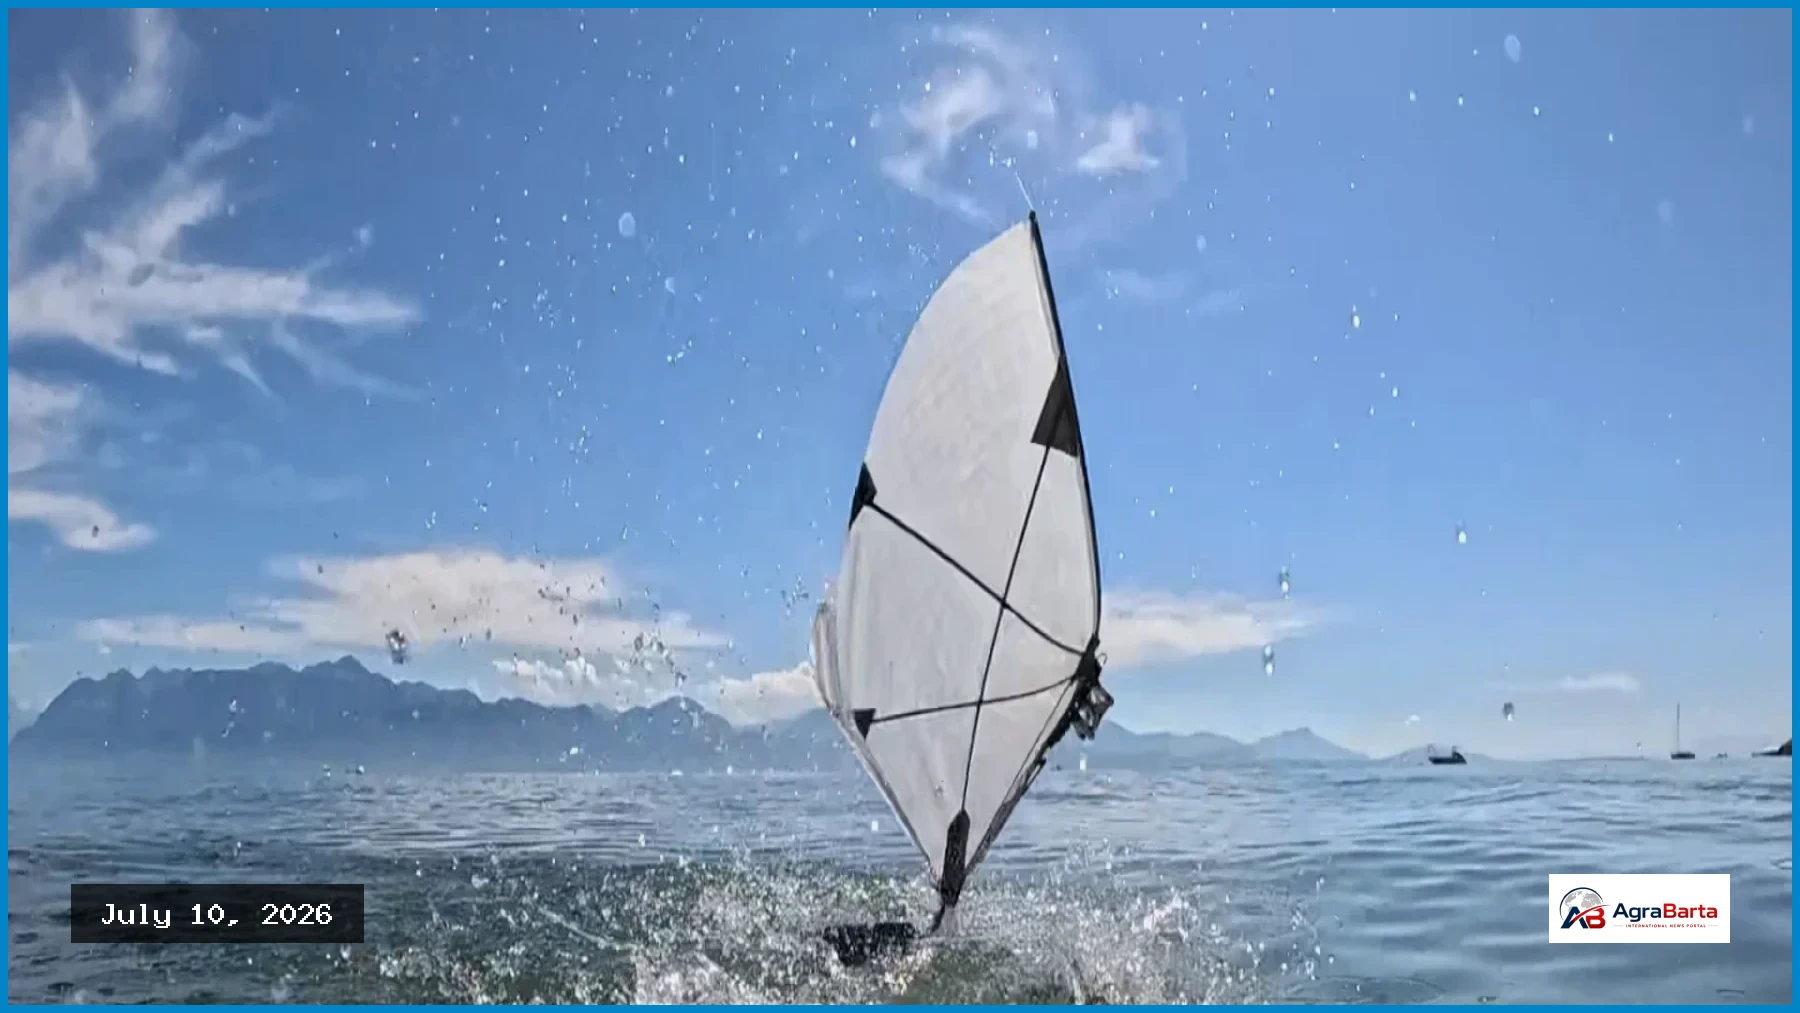
MIT mechanical engineers have developed a novel, bird-sized robot capable of both flying through the air and swimming underwater, successfully transitioning between the two environments using only its wings. This new technology was tested in Switzerland’s Lake Geneva, where it successfully burst from beneath the water’s surface into the air in under a second, backdropped by the distant Alps.
Detailed in a paper published Thursday in the journal Science, the robot weighs about half a pound and has a wingspan of nearly three feet from tip to tip. The project was led by Raphael Zufferey, a mechanical engineer at MIT whose lab features a giant tank of bright turquoise water, wind-generating fans, and various small flying robots.
The team drew inspiration from diving seabirds like the Atlantic puffin, which utilizes its wings for both aerial flight and underwater swimming. Creating this robot took two years. “Thinking of a wing that could operate in both [air and water] somewhat efficiently seems implausible,” Zufferey recalls thinking. “These puffins solve this really challenging task of moving in air, in water despite the huge difference in density,” Zufferey said.
To overcome these challenges, the engineers made two major departures from actual bird anatomy. First, they opted not to include legs, which are notoriously difficult to build and control in robotics. Instead, they designed the robot to transition directly from water to air using only its wings. Second, they avoided the complexity of folding wings, which would require heavy joints and motors, choosing instead to rely on wing flexibility. The resulting wings are made of a translucent nylon fabric reinforced with carbon fiber struts, and the robot features a tail to help it fly.
The robot’s central body, which houses the motor and battery, is completely open, leaving the electronic components visible. “So water floods the whole system here,” Zufferey explained. “You have to waterproof, individually, every single component.” This open-body design keeps the robot light enough to fly while remaining neutrally buoyant in water, meaning it stays suspended without floating to the top or sinking to the bottom.
To maintain normal flight, the robot flaps its wings five to six times per second. However, to escape the water’s drag and propel itself into the air, it must increase its flapping speed to ten times per second to generate the necessary thrust. While most diving birds must run across the water’s surface with their legs to build up takeoff speed—with the exceptionally light kingfisher being a rare exception—this robot achieves lift-off using its wings alone.
On a single charge, the robot is estimated to be capable of flying for nearly four miles or swimming for slightly over a mile. Clifton, a researcher who evaluated the project, observed that this distance “is longer than the running and swimming portion of a sprint triathlon.” Clifton praised the creation as “light and powerful and a monumental step in the performance at both swimming, flying, and transitioning between the two.”
Down the road, Zufferey is excited about using this kind of robot for a range of applications, including monitoring harmful algal blooms, fish stocks, and coastal erosion. He plans to equip the device with a handful of onboard sensors to enable such data gathering. Other potential future applications include observing whale pods and surveying remote coral reefs. Such bio-inspired robots are fertile ground to learn about both nature and engineering. “The biology inspires the robotics,” says Clifton, “but then also the robotics are used to understand the biology.” For Zufferey, the natural world remains the ultimate proof of concept: “You see that it has already been done in biology. So that gives you hope as a robotics researcher. It tells you that it should be possible.”